Robot-Motion-Uncertainty-Aware Informative Path Planning with Guaranteed Estimation Uncertainty

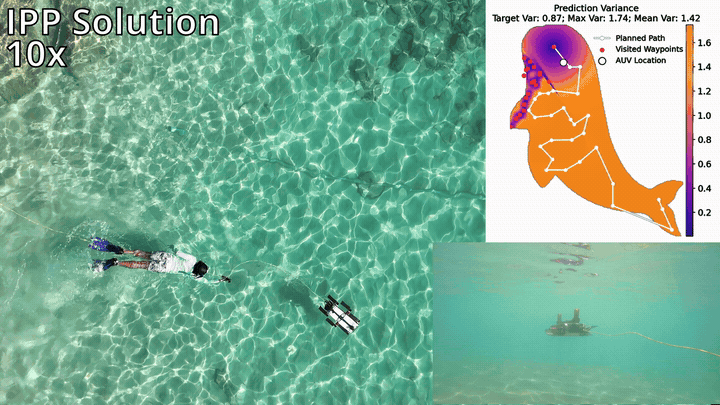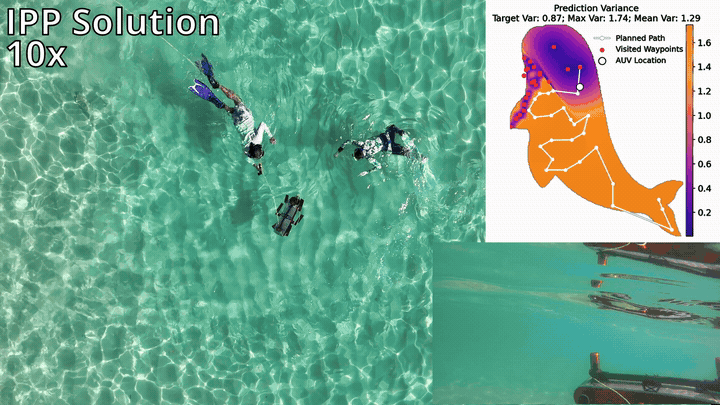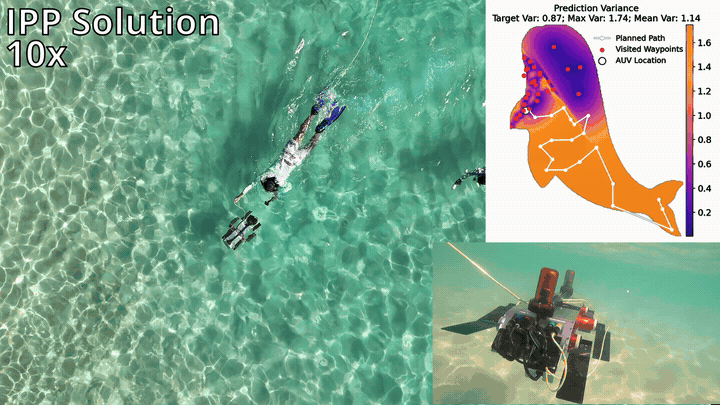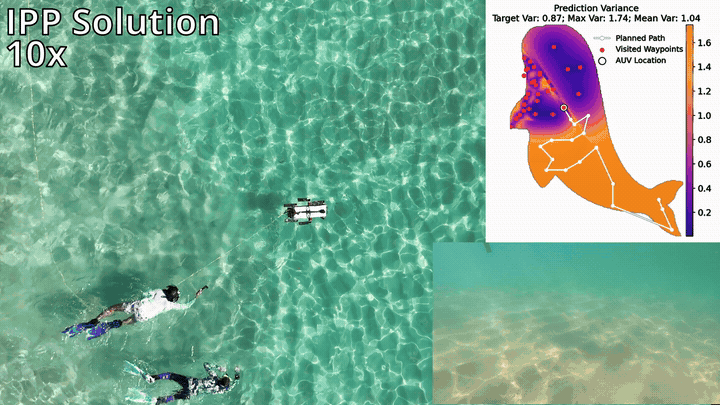
Environmental monitoring robots often need to estimate data fields (e.g., salinity, temperature, bathymetry) under tight resource constraints and operational uncertainty from localization error, actuation noise, and disturbances. Classical lawnmower surveys provide geometric coverage guarantees but can oversample predictable regions. Informative path planning (IPP) leverages spatial correlations to reduce such redundancy, but typically offers no estimation-quality guarantees, especially when robot motion is stochastic. This paper addresses motion-uncertainty-aware IPP with guaranteed estimation uncertainty in complex environments$:$ computing a shortest path whose measurements ensure that the Gaussian process (GP) posterior variance—an intrinsic uncertainty measure that lower-bounds the mean-squared prediction error \ka{under the GP model}—remains below a user-specified threshold over the monitoring region, even under execution noise.