Informative Path Planning with Gaussian Processes: Error Bounds, Algorithms, and Benchmarks

Kalvik Jakkala
Jennifer Wakulicz
Donald G. Dansereau
Srinivas Akella
Lantao Liu
Jason O'Kane
Abstract
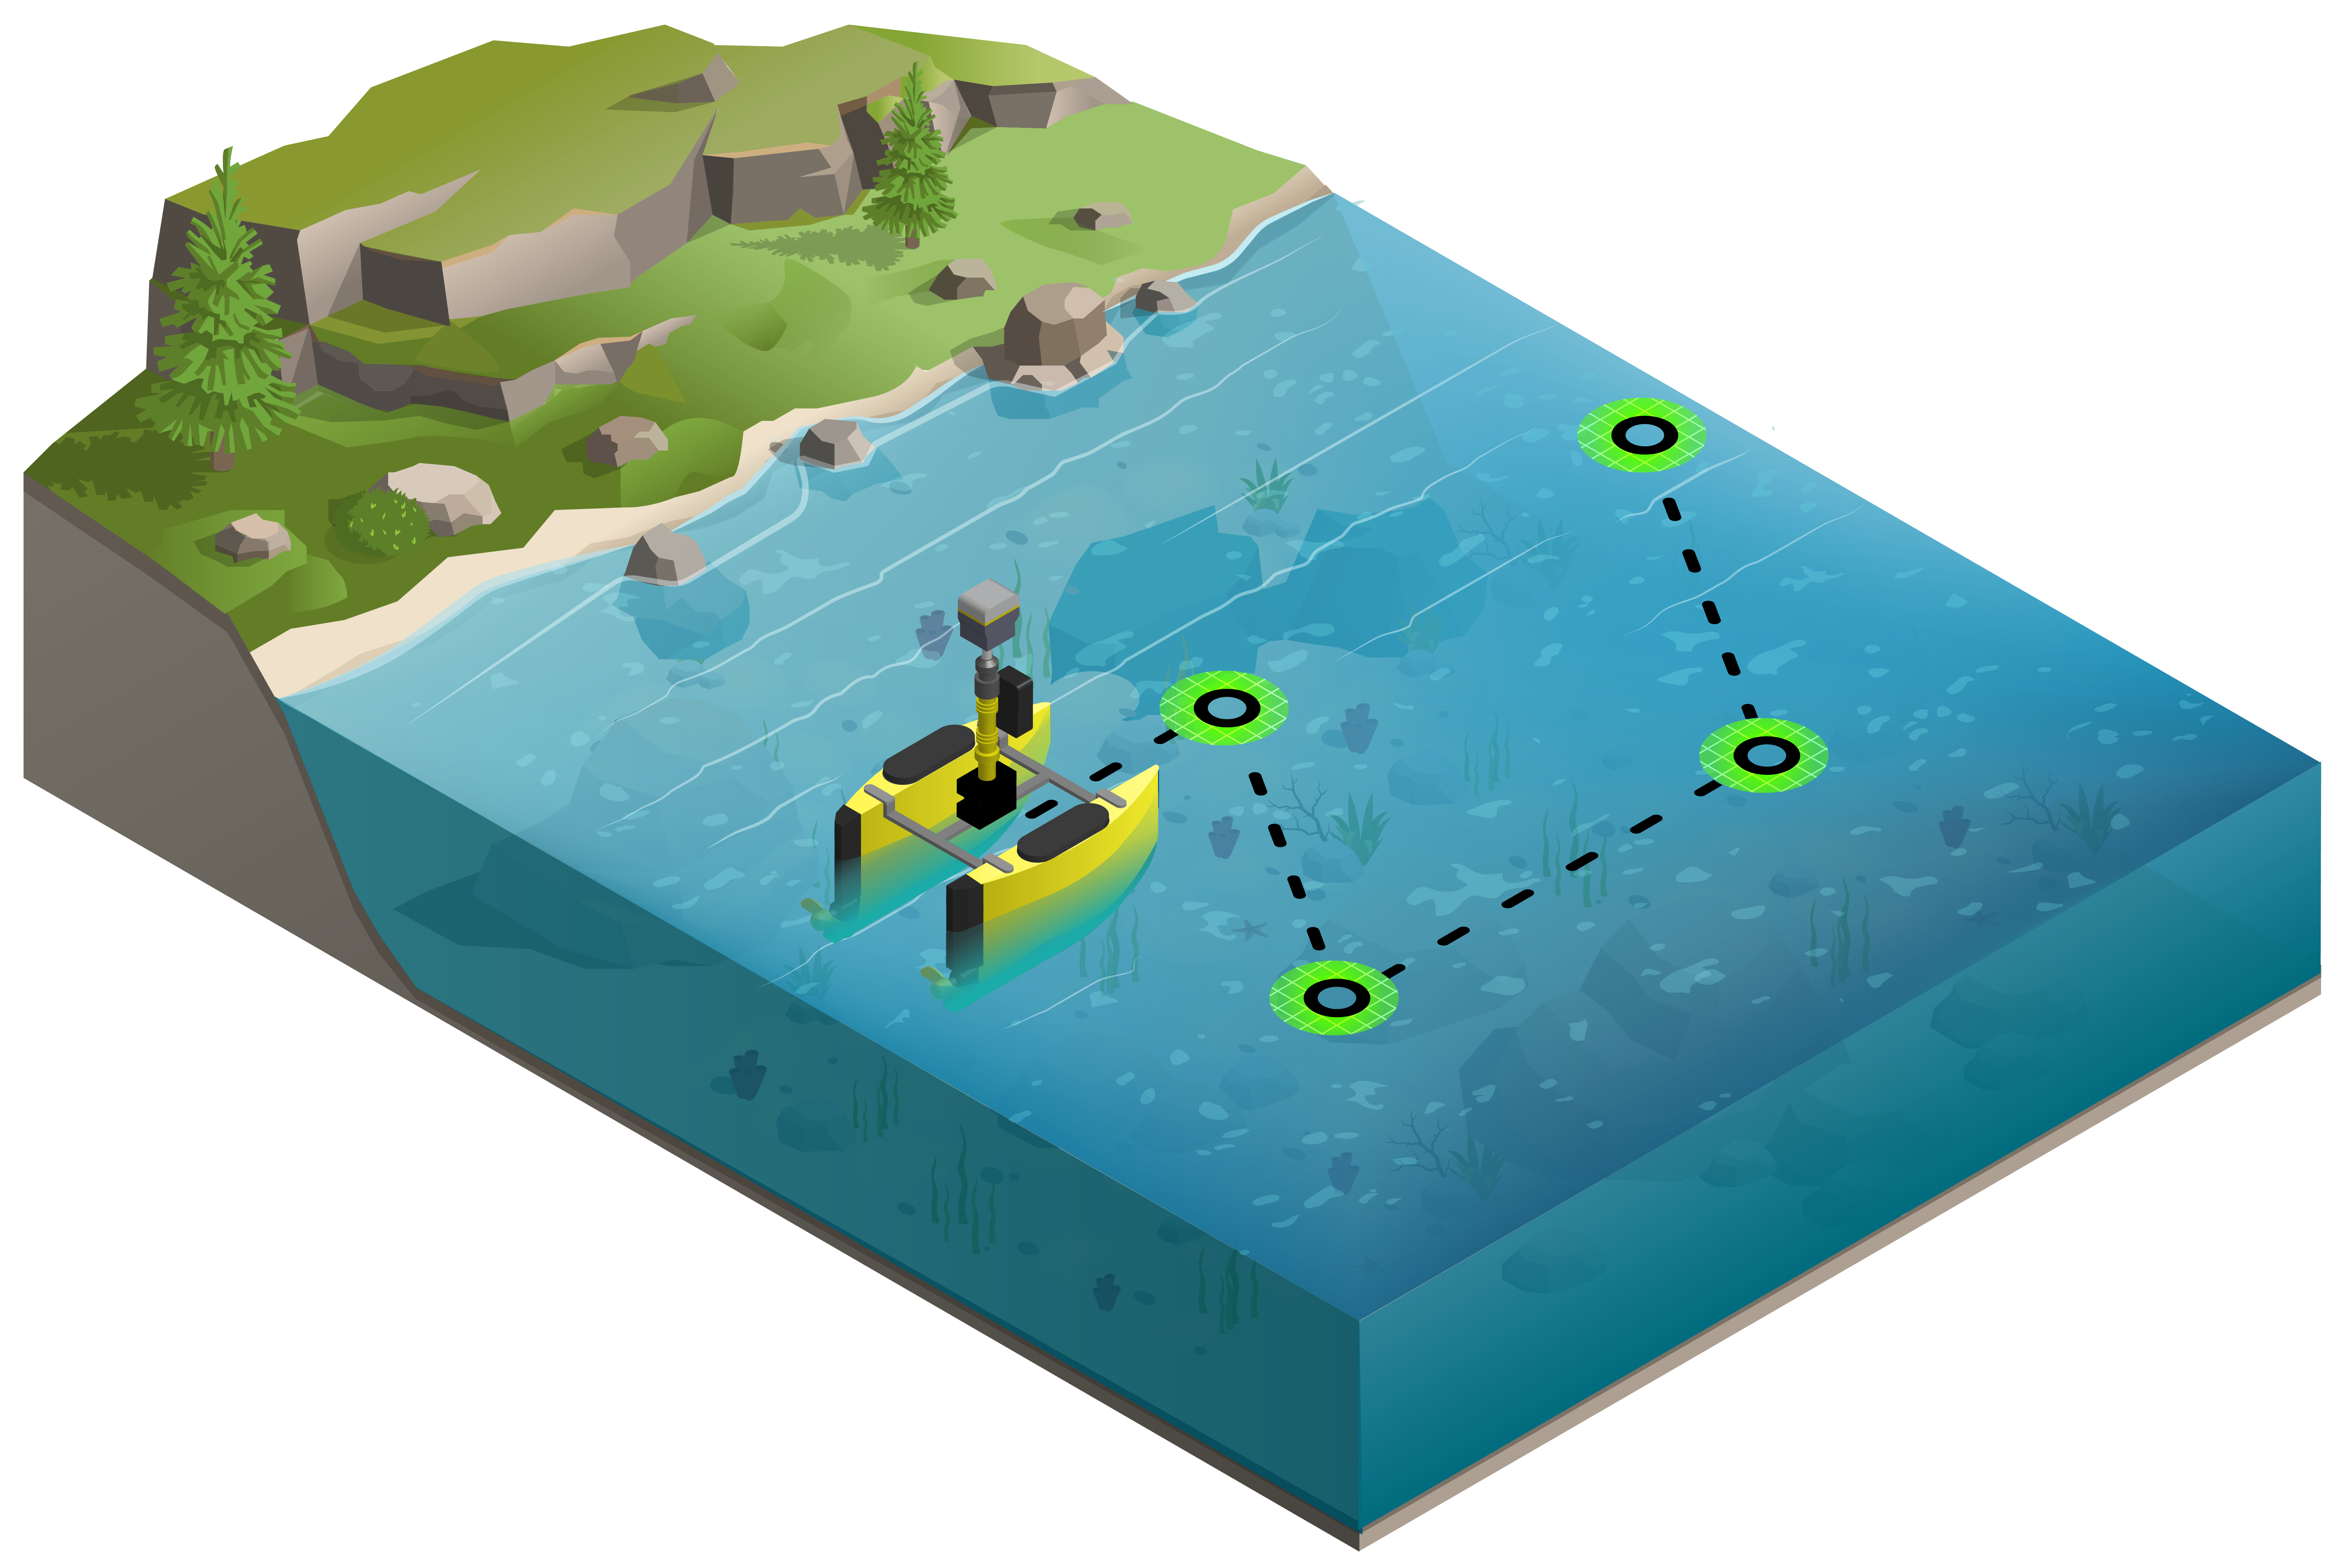
Accurate environmental monitoring relies on Informative Path Planning (IPP) to deploy autonomous systems that maximize information gain. While Gaussian Processes (GPs) provide a robust mathematical foundation for modeling the environment, contemporary IPP approaches remain hindered by heuristic operational constraints and the lack of simultaneous theoretical guarantees for worst-case estimation error and approximation quality. Rather than introducing yet another heuristic, this paper presents a rigorous theoretical analysis of existing error bounds and algorithms to further develop the mathematical foundation for IPP.